Runhan HuangI am a first-year Ph.D. student at My research interests center on Robotics, Generative Models and Reinforcement Learning. My goal is to develop robotic systems that can interact robustly and plan effectively in real-world environments, achieving generalizable and adaptable behaviors. Feel free to reach out if you want to chat about research or collaboration! |
|

Recent News
|
Research Experience
Tsinghua University
Research Assistant, MARS Lab
Oct. 2025 - May 2026
Supervised by Prof. Hang Zhao, working on robot manipulation.

Harvard University
Visiting Researcher, Kempner AI Institute
Mar. 2025 - Oct. 2025

Shanghai Qizhi Institute
Research Assistant, MARS Lab, Tsinghua & Shanghai Qizhi Institute
Jun. 2024 - Mar. 2025
Supervised by Prof. Hang Zhao, working on robot locomotion and robot manipulation.
|
Education
Harvard University
Ph.D. in Computer Science
2026 - Present
Supervised by Prof. Yilun Du.
Tsinghua University
B.Eng. in Computer Science, Yao Class
2022 - 2026
Supervised by Prof. Hang Zhao.
|
Research* indicates equal contribution, † indicates equal advising, and highlight indicates representative papers. |
|
World Action Planner: Generalizable Robot Decision-Making with Action-Conditioned World Models
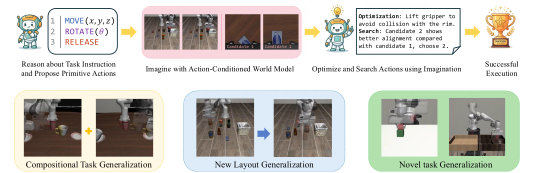
Xiangcheng Zhang*, Runhan Huang*, Yilun Du arXiv, 2026 project page / paper / code World Action Planner is an agentic robot planning system that searches for and composes executable action plans through imagination with an action-conditioned world model, generalizing to compositional long-horizon tasks, novel layouts, and new real-robot tasks without expert demonstrations. |
|
|
SkillX: Unified Multi-Skill Policy Learning for Humanoid Soccer
Zhangchen Ye*, Enxuan Ruan*, Yifei Bao*, Runhan Huang, Jiankun Yang, Jiakang Jin, Yixiao Huo, Pengyuan Wang, Yinan Han, Huaxing Huang, Wenhao Cui, Yiming Li†, Xiaoyu Tian† CoRL 2026 project page / arXiv SkillX learns and composes diverse humanoid soccer skills within a unified command-conditioned policy, enabling robust long-horizon execution and sim-to-real deployment. |
|
|
Generative Control as Optimization: Time-Unconditional Flow Matching for Adaptive and Robust Robotic Control
Zunzhe Zhang*, Runhan Huang*, Yicheng Liu, Shaoting Zhu, Linzhan Mou, Hang Zhao NeurIPS 2026 project page / arXiv GeCO proposes a time-unconditional flow-matching framework that turns robotic action generation into iterative optimization, enabling adaptive inference, improved robustness, and intrinsic out-of-distribution awareness. |
|
|
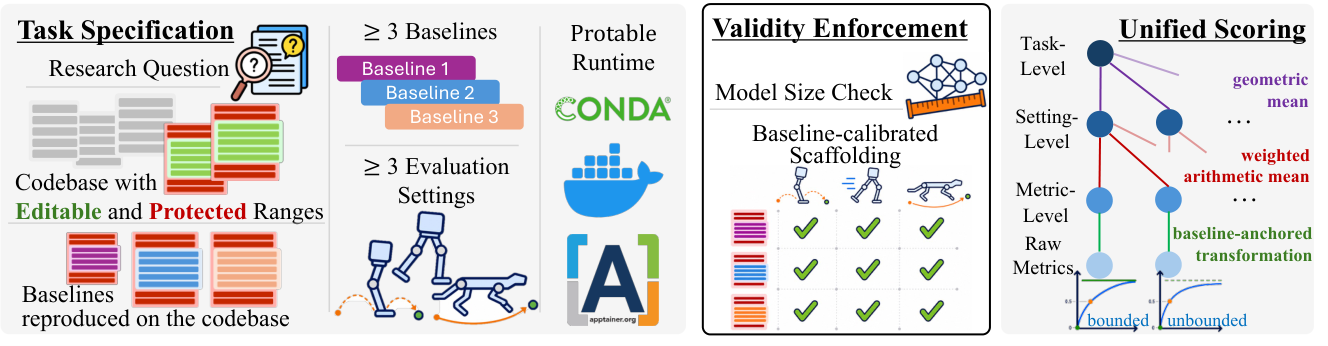
MLS-Bench: A Holistic and Rigorous Assessment of AI Systems on Building Better AI
Bohan Lyu*, Yucheng Yang*, Siqiao Huang*, Jiaru Zhang*, Qixin Xu*, Xinghan Li*, Xinyang Han*, Yicheng Zhang*, Huaqing Zhang*, Runhan Huang, Kaicheng Yang, Zitao Chen, Wentao Guo, Junlin Yang, Xinyue Ai, Wenhao Chai, Yadi Cao, Ziran Yang, Kun Wang, Dapeng Jiang, Huan-ang Gao, Shange Tang, Chengshuai Shi, Simon S. Du, Max Simchowitz, Jiantao Jiao, Dawn Song, Chi Jin NeurIPS 2026Oral · Top 0.36% project page / arXiv / code MLS-Bench evaluates whether AI systems can invent generalizable and scalable machine learning methods across diverse research tasks. |
|
|
|
TTT-Parkour: Rapid Test-Time Training for Perceptive Robot Parkour
Shaoting Zhu*, Baijun Ye*, Jiaxuan Wang†, Jiakang Chen†, Ziwen Zhuang, Linzhan Mou, Runhan Huang, Hang Zhao CoRL 2026 project page / video / arXiv TTT-Parkour proposes a real-to-sim-to-real framework that leverages rapid test-time training (TTT) on novel terrains, significantly enhancing the robot's capability to traverse extremely difficult geometries. |
|
|
Flexible Locomotion Learning with Diffusion Model Predictive Control
Runhan Huang, Haldun Balim, Heng Yang, Yilun Du ICRA 2026 project page / video / arXiv / code / media coverage Diffusion MPC introduces a test-time adaptable locomotion planner grounded in a diffusion-based generative prior. An interactive training procedure further improves the performance of diffusion-based planners. |
|
|
MoELoco: Mixture of Experts for Multitask Locomotion
Runhan Huang*, Shaoting Zhu*, Yilun Du, Hang Zhao IROS 2025 project page / video / arXiv / code MoELoco introduces a multitask locomotion framework that employs a mixture-of-experts strategy to enhance reinforcement learning across diverse tasks while leveraging compositionality to generate new skills. |
|
|
VR-Robo: A Real-to-Sim-to-Real Framework for Visual Robot Navigation and Locomotion
Shaoting Zhu*, Linzhan Mou*, Derun Li, Baijun Ye, Runhan Huang, Hang Zhao RA-L 2025 project page / video / arXiv / code VR-Robo introduces a digital twin framework using 3D Gaussian Splatting for photorealistic simulation, enabling RGB-based sim-to-real transfer for robot navigation and locomotion. |
|
|
Robust Robot Walker: Learning Agile Locomotion over Tiny Traps
Shaoting Zhu, Runhan Huang, Linzhan Mou, Hang Zhao ICRA 2025 project page / video / arXiv / code RRW introduces a proprioception-only, two-stage training framework with goal command and a dedicated tiny trap benchmark, enabling quadruped robots to robustly traverse small obstacles. |
Miscellanea |
Academic Service |
Reviewer, RA-L
Reviewer, JAIR Reviewer, ICLR 2026 Reviewer, CoRL 2026 Reviewer, NeurIPS 2026 |